ROBOTICS · REAL-TIME MOTION

Motion that arrives
on time.

We develop intelligent manipulators, embodied robots, service delivery robots and AGV platforms with EtherCAT®-based real-time control and integrated hardware-software engineering.

  • Intelligent Manipulators
  • Embodied Robots
  • Delivery Robots & AGVs
  • EtherCAT® Motion Control
Pingxiang · Jiangxi · ChinaActive robot-control R&D and system integration
CONTROL FABRICReal-time motion-control chain
SYSTEM
MAINDEVICEMotion ControllerTrajectory · Cyclic task
CONTROL CYCLESYNC
EtherCAT
SUBDEVICE 01Servo DriveJoint / Linear axis
SUBDEVICE 02Servo DriveJoint / Linear axis
SUBDEVICE NI/O ModuleSensor / End effector
DCDISTRIBUTED CLOCKS
Cyclic data Multi-axis sync Status feedback
01 / TECHNOLOGY

Connecting control,
drives, I/O and sensing.

We use EtherCAT® as the communication backbone for coordinated robot joints, cyclic process data and device-state management.

Four robot product directions,
from manipulation to mobility.

Current R&D covers intelligent manipulators, embodied robots, service delivery robots and AGV platforms, together with EtherCAT® servo networks, field I/O, commissioning and validation.

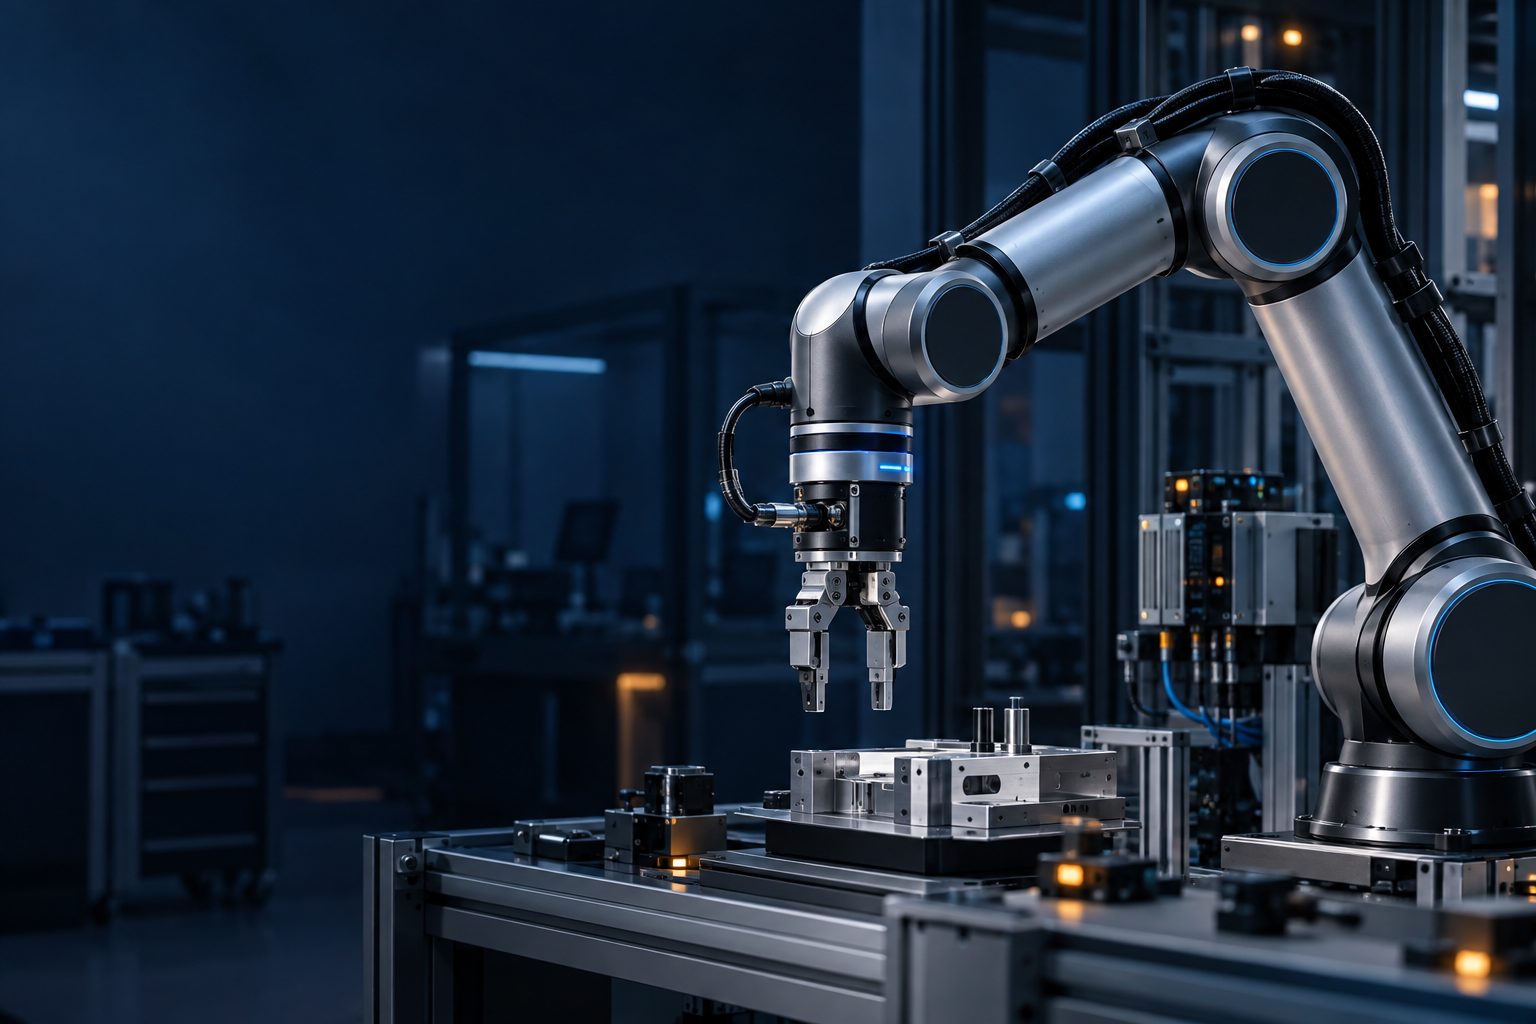
Intelligent manipulator for precision assembly
PRODUCT & SERVICE
P / 01

SMART MANIPULATOR

Intelligent Manipulators

Multi-axis execution platforms and control-system development for precision operation, joint control, end effectors and task workflows.

  • Coordinated joints and end effectors
  • EtherCAT® servo-network integration
  • Gripping, assembly and machine tending
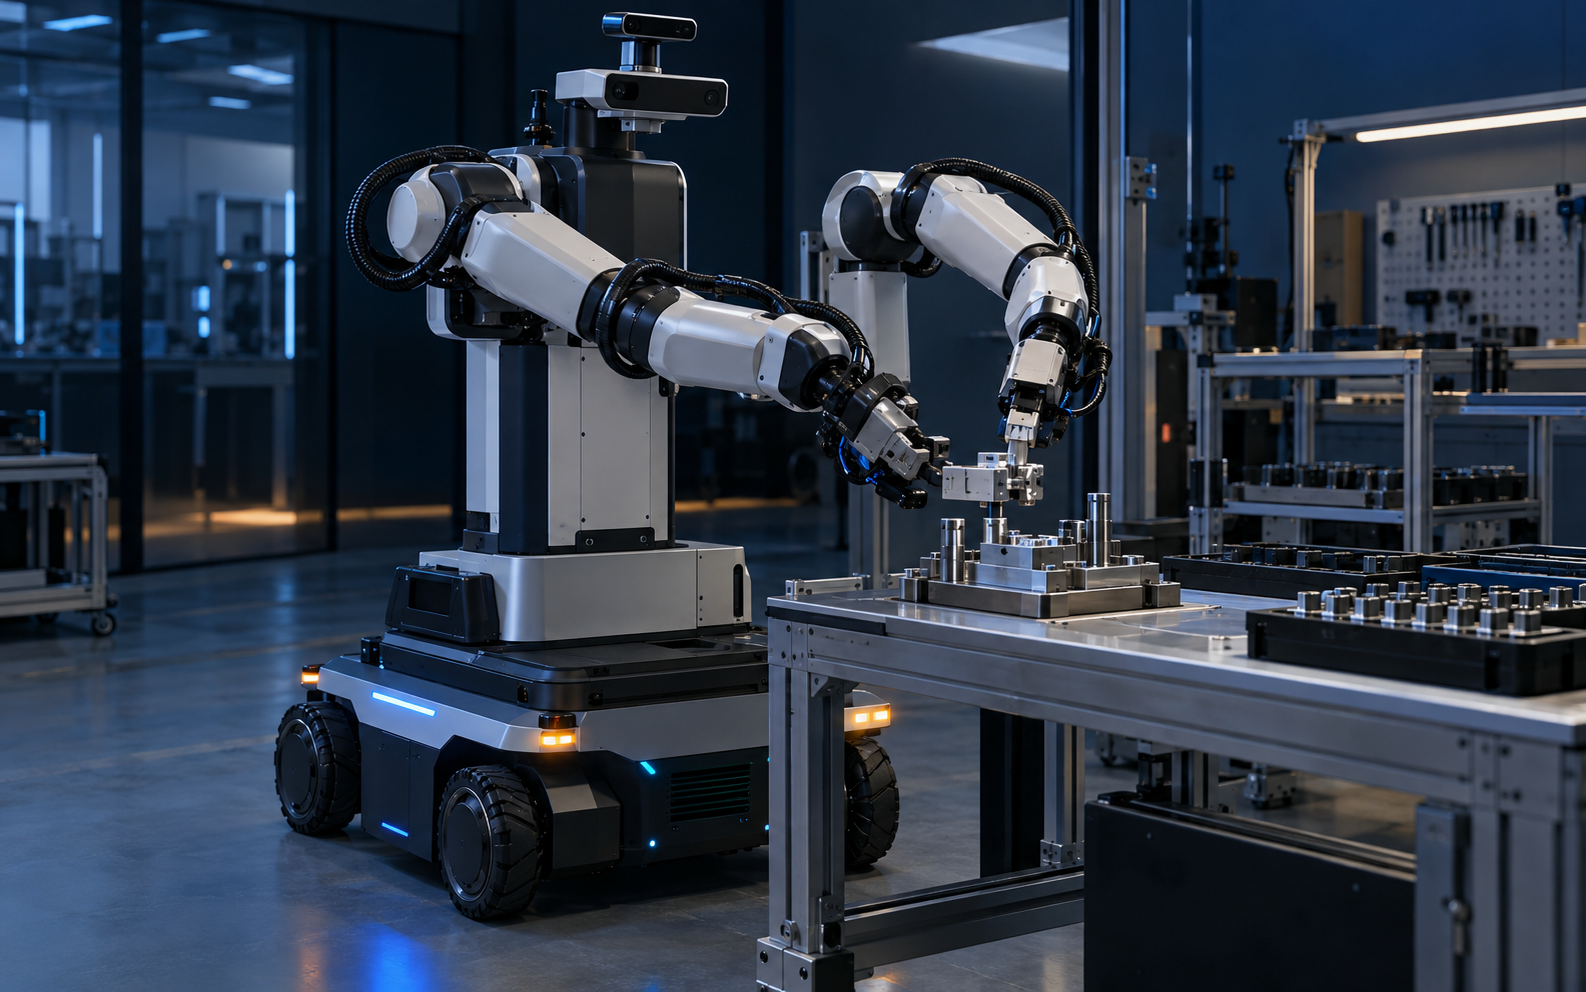
Dual-arm mobile embodied robot performing precision work
PRODUCT & SERVICE
P / 02

EMBODIED ROBOT

Embodied Robots

Integrated systems that connect perception, planning, control and execution for mobile manipulation, dual-arm collaboration and application-specific tasks.

  • Perception and motion-control loop
  • Mobile base and manipulator coordination
  • R&D validation and application integration
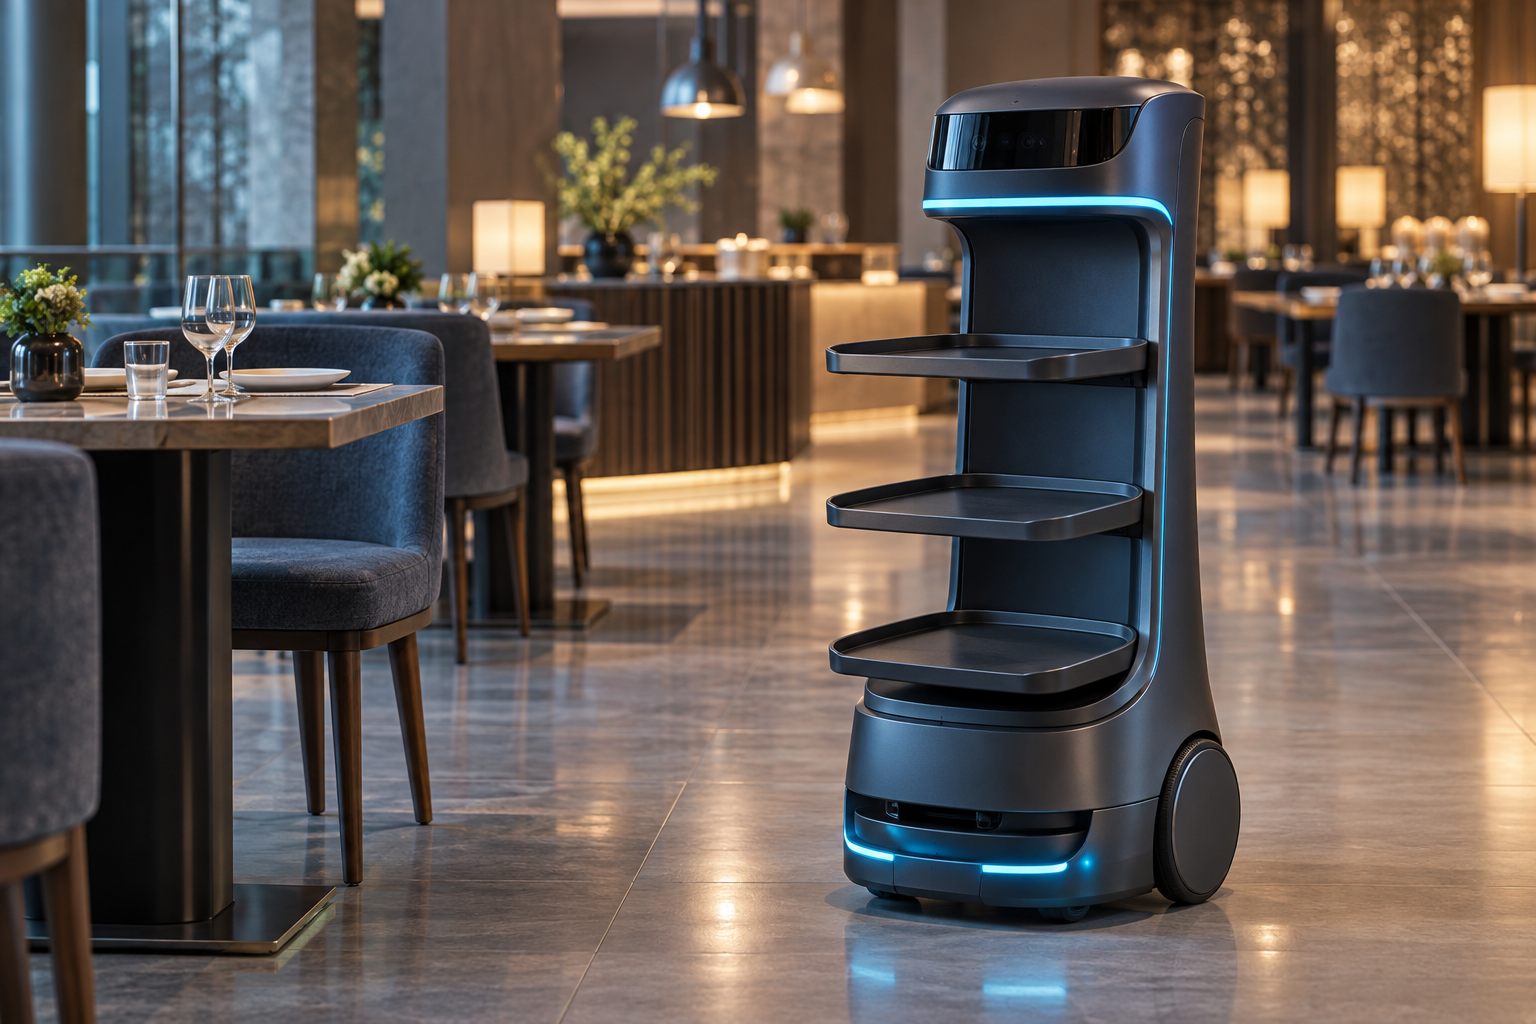
Indoor service delivery robot in a restaurant setting
R&D PRODUCT DIRECTION
P / 03

SERVICE DELIVERY ROBOT

Service Delivery Robots

Mobile delivery platforms for restaurants and indoor service environments, integrating autonomous mobility, task dispatch, multi-level trays and human-machine interaction.

  • Mobile base, navigation and obstacle-avoidance interfaces
  • Tray, light, voice and field-I/O coordination
  • Real-time interfaces for drives and actuators
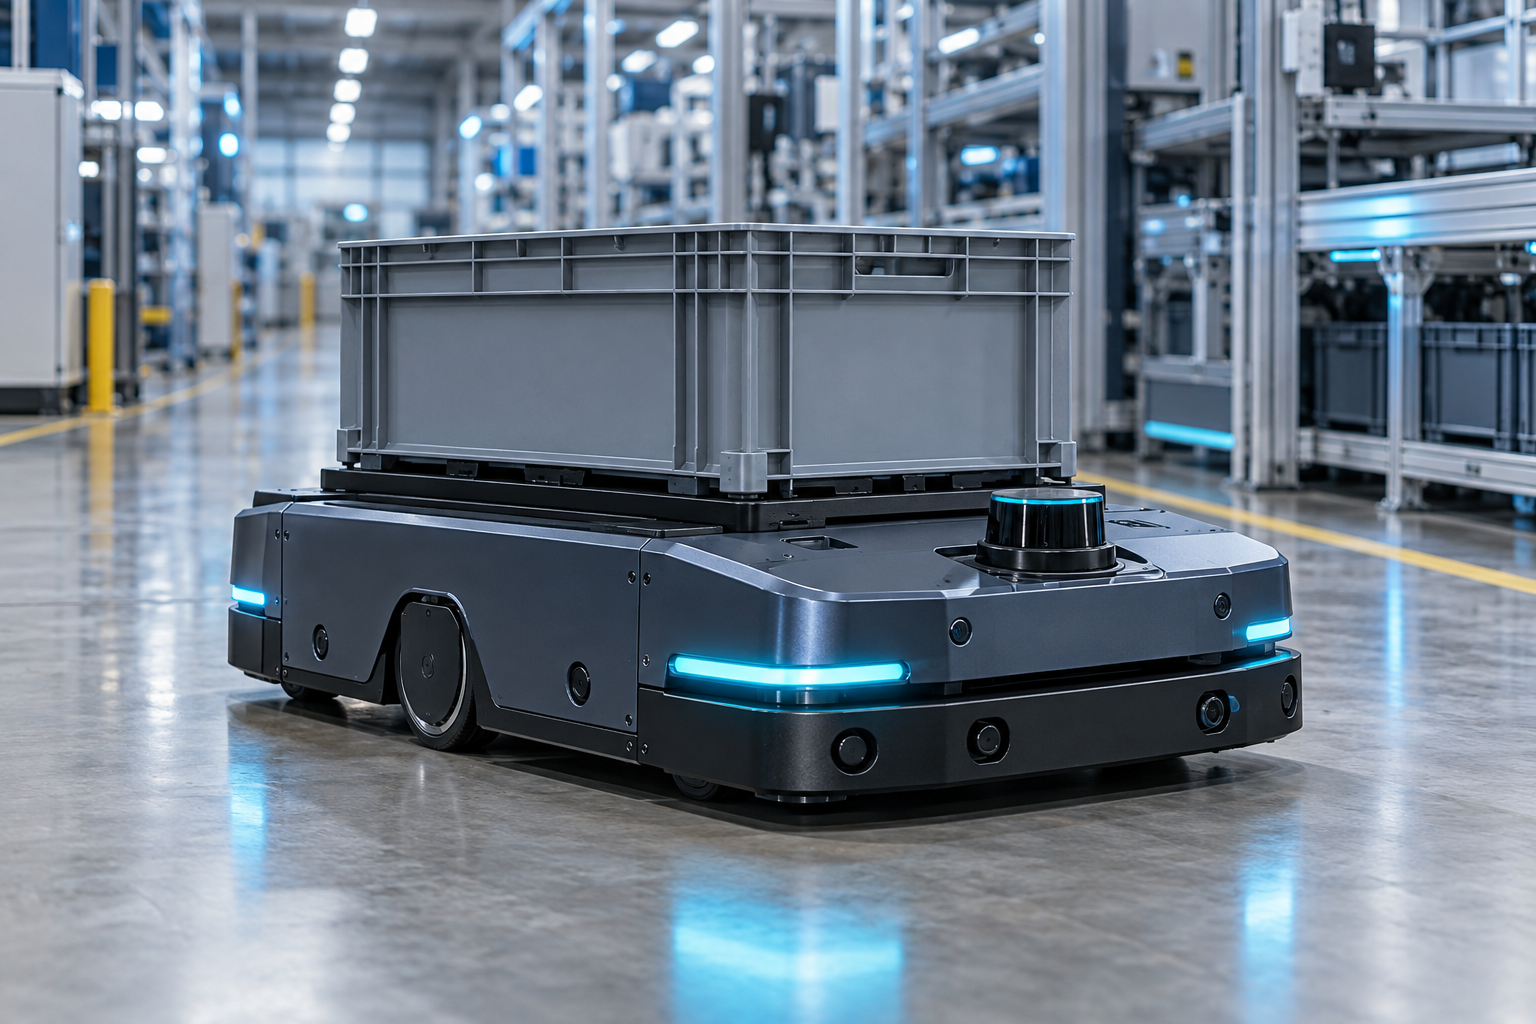
AGV mobile robot transporting material in a factory
R&D PRODUCT DIRECTION
P / 04

AGV / AMR PLATFORM

AGV / AMR Platforms

Mobile-robot platforms for shop-floor material flow and line-side delivery, with engineering integration for chassis, lift or conveyor modules and supervisory systems.

  • Differential-drive or steer-drive motion control
  • Lift, conveyor and safety-sensor integration
  • EtherCAT® drives and field-I/O integration

A clear and diagnosable
real-time control chain.

Our engineering scope includes EtherCAT® MainDevice integration, ESI handling, cyclic process-data mapping, Distributed Clocks, and validation of servo drives, I/O and sensing devices for multi-axis robot control.

MainDevice IntegrationESI ConfigurationPDO Process DataDistributed ClocksCoE / CiA 402Status & Diagnostics
L4 · APPLICATIONRobot Task LayerTask orchestration · Perception · APIs
L3 · MOTIONReal-Time Motion LayerTrajectory · Coordination · Feedback
L2 · NETWORKEtherCAT® LayerProcess data · DC · State machine
L1 · DEVICEField Device LayerDrives · I/O · Encoders · Sensors
01

MainDevice & Topology

MainDevice software, network topology and device-data relationships for robot joints, end effectors and field I/O.

02

ESI, PDO & Devices

Device-description handling and cyclic process-data configuration for drives, encoders, digital and analog I/O.

03

Clocks & Coordination

Distributed Clocks as a time base for synchronized multi-joint robot motion and coordinated acquisition.

04

State & Diagnostics

Device states, communication events and runtime information for commissioning, validation and maintenance.

Applying real-time control
to concrete robot tasks.

These are representative target applications used to describe our product and engineering scope; they are not presented as delivered customer references.

A / 01

Precision Assembly

Coordinating manipulators, fixtures, vision and field I/O for positioning, insertion and assembly.

PRECISION ASSEMBLY
A / 02

Smart Intralogistics

AGV / AMR platforms linking storage, production lines and workstations through drive, lift, conveyor and field-I/O integration.

INTRALOGISTICS
A / 03

Food & Indoor Delivery

Service workflows for restaurants and hotels combining task dispatch, indoor navigation, obstacle avoidance and user interaction.

INDOOR DELIVERY
A / 04

Embodied-AI Research

Execution platforms for perception, planning and control algorithms in physical robot systems.

EMBODIED RESEARCH

From system boundaries
to verifiable motion.

  1. 01

    Task & Boundary Definition

    Define robot tasks, objects, cycle constraints, axis count and site interfaces.

  2. 02

    Control Architecture

    Plan the controller, EtherCAT® network, drives, I/O and sensing relationships.

  3. 03

    Integration & Validation

    Validate communication, single-axis motion, coordinated axes and abnormal states in stages.

  4. 04

    Application Integration

    Connect task software, perception and site workflows into a complete robot application.

Active development of robot products
and real-time control systems.

Active R&D and technical cooperationWebsite updated: 16 September 2026
01 / MANIPULATION

Manipulator Control Platform

Architecture and validation work for multi-axis servos, joint control, end effectors and task workflows.

02 / EMBODIED ROBOTICS

Embodied-Robot Integration

Software and hardware interfaces linking perception, planning, mobile bases, manipulators and motion execution.

03 / INDUSTRIAL NETWORK

EtherCAT Engineering Validation

Integration validation covering MainDevice, servo drives, I/O, cyclic process data and Distributed Clocks.

ETHERCAT PROJECT INTENTIONWhy we are applying for ETG membership

We intend to use EtherCAT as the real-time fieldbus for multi-axis robot control, connecting servo drives, I/O and sensing devices through cyclic process data and Distributed Clocks. We are applying for ETG membership to access official specifications and implementation guidance, participate in technical exchange, and develop our integration work in accordance with ETG requirements.

JYROBOTICS

Robot motion and
real-time control technology.

The company was established on 7 July 2020 in Pingxiang, Jiangxi, China. Our product R&D covers intelligent manipulators, embodied robots, service delivery robots and AGV platforms, together with EtherCAT®-based motion-control integration.

With registered capital of RMB 1,000,000, the company is actively engaged in robot-product R&D, control-system validation and technical cooperation across control software, industrial networks, drives and actuators.

Legal name
萍乡市金简云网络科技有限公司
Established
7 July 2020
Registered capital
RMB 1,000,000
Registered address
No. 14, Shaotangchong, Jiancun Village, Jinshan Town, Shangli County, Pingxiang, Jiangxi, China
Products
Intelligent manipulators · Embodied robots · Service delivery robots · AGV / AMR platforms
Technology
EtherCAT® multi-axis real-time control
Status
Active product R&D and technical cooperation
From control commands
to physical motion.

Contact us about intelligent manipulators, embodied robots, EtherCAT® control-system integration and R&D validation.

COOPERATION
  • Product and application requirements
  • EtherCAT® control-system integration
  • Joint robot R&D and validation
  • ETG and industrial ecosystem exchange
LEGAL ENTITY & REGISTERED ADDRESS萍乡市金简云网络科技有限公司No. 14, Shaotangchong, Jiancun Village, Jinshan Town, Shangli County, Pingxiang, Jiangxi, China